
Office Elevator model, compiled 2026-09-27T22:48:31 with SBDL 1.27.12 (DSL 26.6). Generated from the SBDL model; every element links to its definition in the materials the model is spread across.
| Identifier | Requirement | Aspect | Verified by | Failure modes |
|---|---|---|---|---|
| sys_req_1 model/generated/requirements.sbdl:2 |
The elevator system shall transport passengers between floors safely and efficiently | elevator_system | ||
| req_capacity refines sys_req_1 model/generated/requirements.sbdl:3 |
The cabin shall carry a rated load of 630 kg (8 persons) | cabin | ||
| req_door_obstruction refines sys_req_1 model/generated/requirements.sbdl:4 |
The door system shall detect an obstruction and reopen within 250 ms | door_system | function: func_door_reopen |
fm_door_no_open |
| req_levelling refines sys_req_1 model/generated/requirements.sbdl:5 |
The cabin shall level within 10 mm of the floor sill | drive_system | ||
| req_dispatch refines sys_req_1 model/generated/requirements.sbdl:6 |
The dispatcher shall minimise average waiting time using collective control | dispatcher | UT::test_call_order | |
| sys_req_3 model/generated/requirements.sbdl:7 |
The elevator system shall provide accessible and intuitive passenger interaction | user_interface | ||
| req_door_hold refines sys_req_3 model/generated/requirements.sbdl:8 |
The doors shall stay open for a configurable dwell time (default 4 s) after a call | door_system | ||
| req_display refines sys_req_3 model/generated/requirements.sbdl:9 |
The cabin display shall show the current floor and direction of travel at all times | display | ||
| sys_req_2 model/safety.sbdl:11 |
The elevator system shall comply with EN 81-20 EN 81-20 SafetyRequirement | elevator_system | ||
| req_safety_brake refines sys_req_2 model/safety.sbdl:17 |
The safety brake shall engage within 100 ms of an overspeed or free-fall detection EN 81-20 5.6.2 SafetyRequirement | brake | UT::test_stop_sequence function: func_emergency_stop |
fm_overspeed |
| req_limit_switch refines sys_req_2 model/safety.sbdl:24 |
Limit switches shall cut drive power on overtravel in either direction EN 81-20 5.12.2 SafetyRequirement | limit_switches | UT::test_fault_cleared function: func_emergency_stop |
|
| req_emergency_power refines sys_req_2 model/safety.sbdl:31 |
The UPS shall sustain safety-critical functions for at least 1 hour after a mains failure EN 81-20 5.10.4 SafetyRequirement | ups | fm_power_loss | |
| req_overload refines sys_req_2 model/safety.sbdl:38 |
The cabin shall not depart when the load exceeds the rated capacity EN 81-20 5.12.1.2 SafetyRequirement | load_sensor |

| Aspect | Description | Part of | Interfaces | Properties |
|---|---|---|---|---|
| elevator_system doc/Architecture.docx:7 |
The office elevator serves eight floors with a single cabin and a traction drive. It is decomposed into six subsystems, described below. | elevator_model | ||
| cabin doc/Architecture.docx:10 |
The cabin carries up to eight passengers. It holds the doors, the lighting, the display and the emergency phone, and rests on a load cell. | elevator_system | ||
| drive_system doc/Architecture.docx:12 |
The traction motor, counterweight, holding brake and speed governor move the cabin and hold it in place. | elevator_system | ||
| control_system «software» doc/Architecture.docx:16 |
A software controller with two independent parts: the dispatcher that schedules calls, and the safety monitor that supervises every sensor and can stop the cabin on its own. | elevator_system | can_bus | |
| shaft doc/Architecture.docx:19 |
The shaft structure with its guide rails, overtravel limit switches and the absolute position encoder. | elevator_system | ||
| user_interface doc/Architecture.docx:22 |
All passenger-facing controls and indicators: hall call panels on each landing, the cabin panel and the overload indicator. | elevator_system | ||
| power_supply «electrical» doc/Architecture.docx:25 |
Mains distribution and the uninterruptible supply that keeps the safety functions and lighting alive when the mains fail. | elevator_system | ||
| door_system model/elevator.sbdl:42 |
Cabin door mechanism and sensors | cabin | custom:rated_cycles = 2000000 cycles |
|
| door_motor «electrical» model/elevator.sbdl:47 |
Door drive motor and belt | door_system | ||
| door_obstruction_sensor Sensor model/elevator.sbdl:48 |
Infrared light curtain across the door opening | door_system | types = Sensor aspect accuracy = 5 mm range = 2000 mm |
|
| lighting «electrical» model/elevator.sbdl:55 |
Cabin interior lighting | cabin | ||
| emergency_phone «safety» model/elevator.sbdl:56 |
In-cabin emergency communication device | cabin | ||
| display «electrical» model/elevator.sbdl:57 |
Floor indicator display inside cabin | cabin | ||
| load_sensor Sensor model/elevator.sbdl:58 |
Load cell under the cabin floor | cabin | types = Sensor aspect range = 1000 kg |
|
| motor «electrical» model/elevator.sbdl:64 |
Traction motor unit | drive_system | ||
| counterweight model/elevator.sbdl:65 |
Counterweight assembly balancing the cabin | drive_system | ||
| brake «safety» model/elevator.sbdl:66 |
Electromechanical holding and safety brake | drive_system | brake_circuit | |
| speed_governor «safety» model/elevator.sbdl:71 |
Centrifugal governor that trips the safety gear on overspeed | drive_system | ||
| dispatcher «software» model/elevator.sbdl:77 |
Floor call scheduling and cabin dispatch logic | control_system | ||
| safety_monitor «software» model/elevator.sbdl:78 |
Real-time safety interlock monitoring | control_system | brake_circuit, can_bus | |
| guide_rails model/elevator.sbdl:85 |
Vertical guide rails for cabin travel | shaft | ||
| limit_switches «safety» model/elevator.sbdl:86 |
Top and bottom overtravel limit switches | shaft | ||
| position_sensor Sensor model/elevator.sbdl:87 |
Absolute cabin position encoder on the guide rail | shaft | can_bus | types = Sensor aspect accuracy = 1 mm range = 60000 mm |
| floor_call_panel model/elevator.sbdl:95 |
Hall call buttons on each floor landing | user_interface | ||
| cabin_panel model/elevator.sbdl:96 |
Destination floor selection buttons inside the cabin | user_interface | ||
| overload_indicator «safety» model/elevator.sbdl:97 |
Passenger overload warning indicator | user_interface | ||
| ups «electrical» model/elevator.sbdl:99 |
Uninterruptible power supply for safety functions | power_supply |
| Definition | Decision | Concerns | Realised by |
|---|---|---|---|
| arch_doc doc/Architecture.docx:3 |
This document describes the subsystems of the office elevator. The SBDL statements in it define the subsystems for the model; their descriptions are taken from the prose around them, so the document and the model cannot disagree. | elevator_system, cabin, drive_system, control_system, shaft, user_interface, power_supply | |
| brake_independence doc/Architecture.docx:29 |
The dispatcher never commands the brake: only the safety monitor does, over a hard-wired circuit. This keeps the safety function independent of scheduling software. | safety_monitor, dispatcher req_safety_brake |
|
| maintenance_manual README.md:72 |
Maintenance manual, section 4: periodic tests | door_system | |
| safety_monitor_design model/elevator.sbdl:113 |
The safety monitor evaluates every sensor frame independently of the dispatcher and can command the brake circuit on its own | safety_monitor req_safety_brake |
SafetyMonitor |

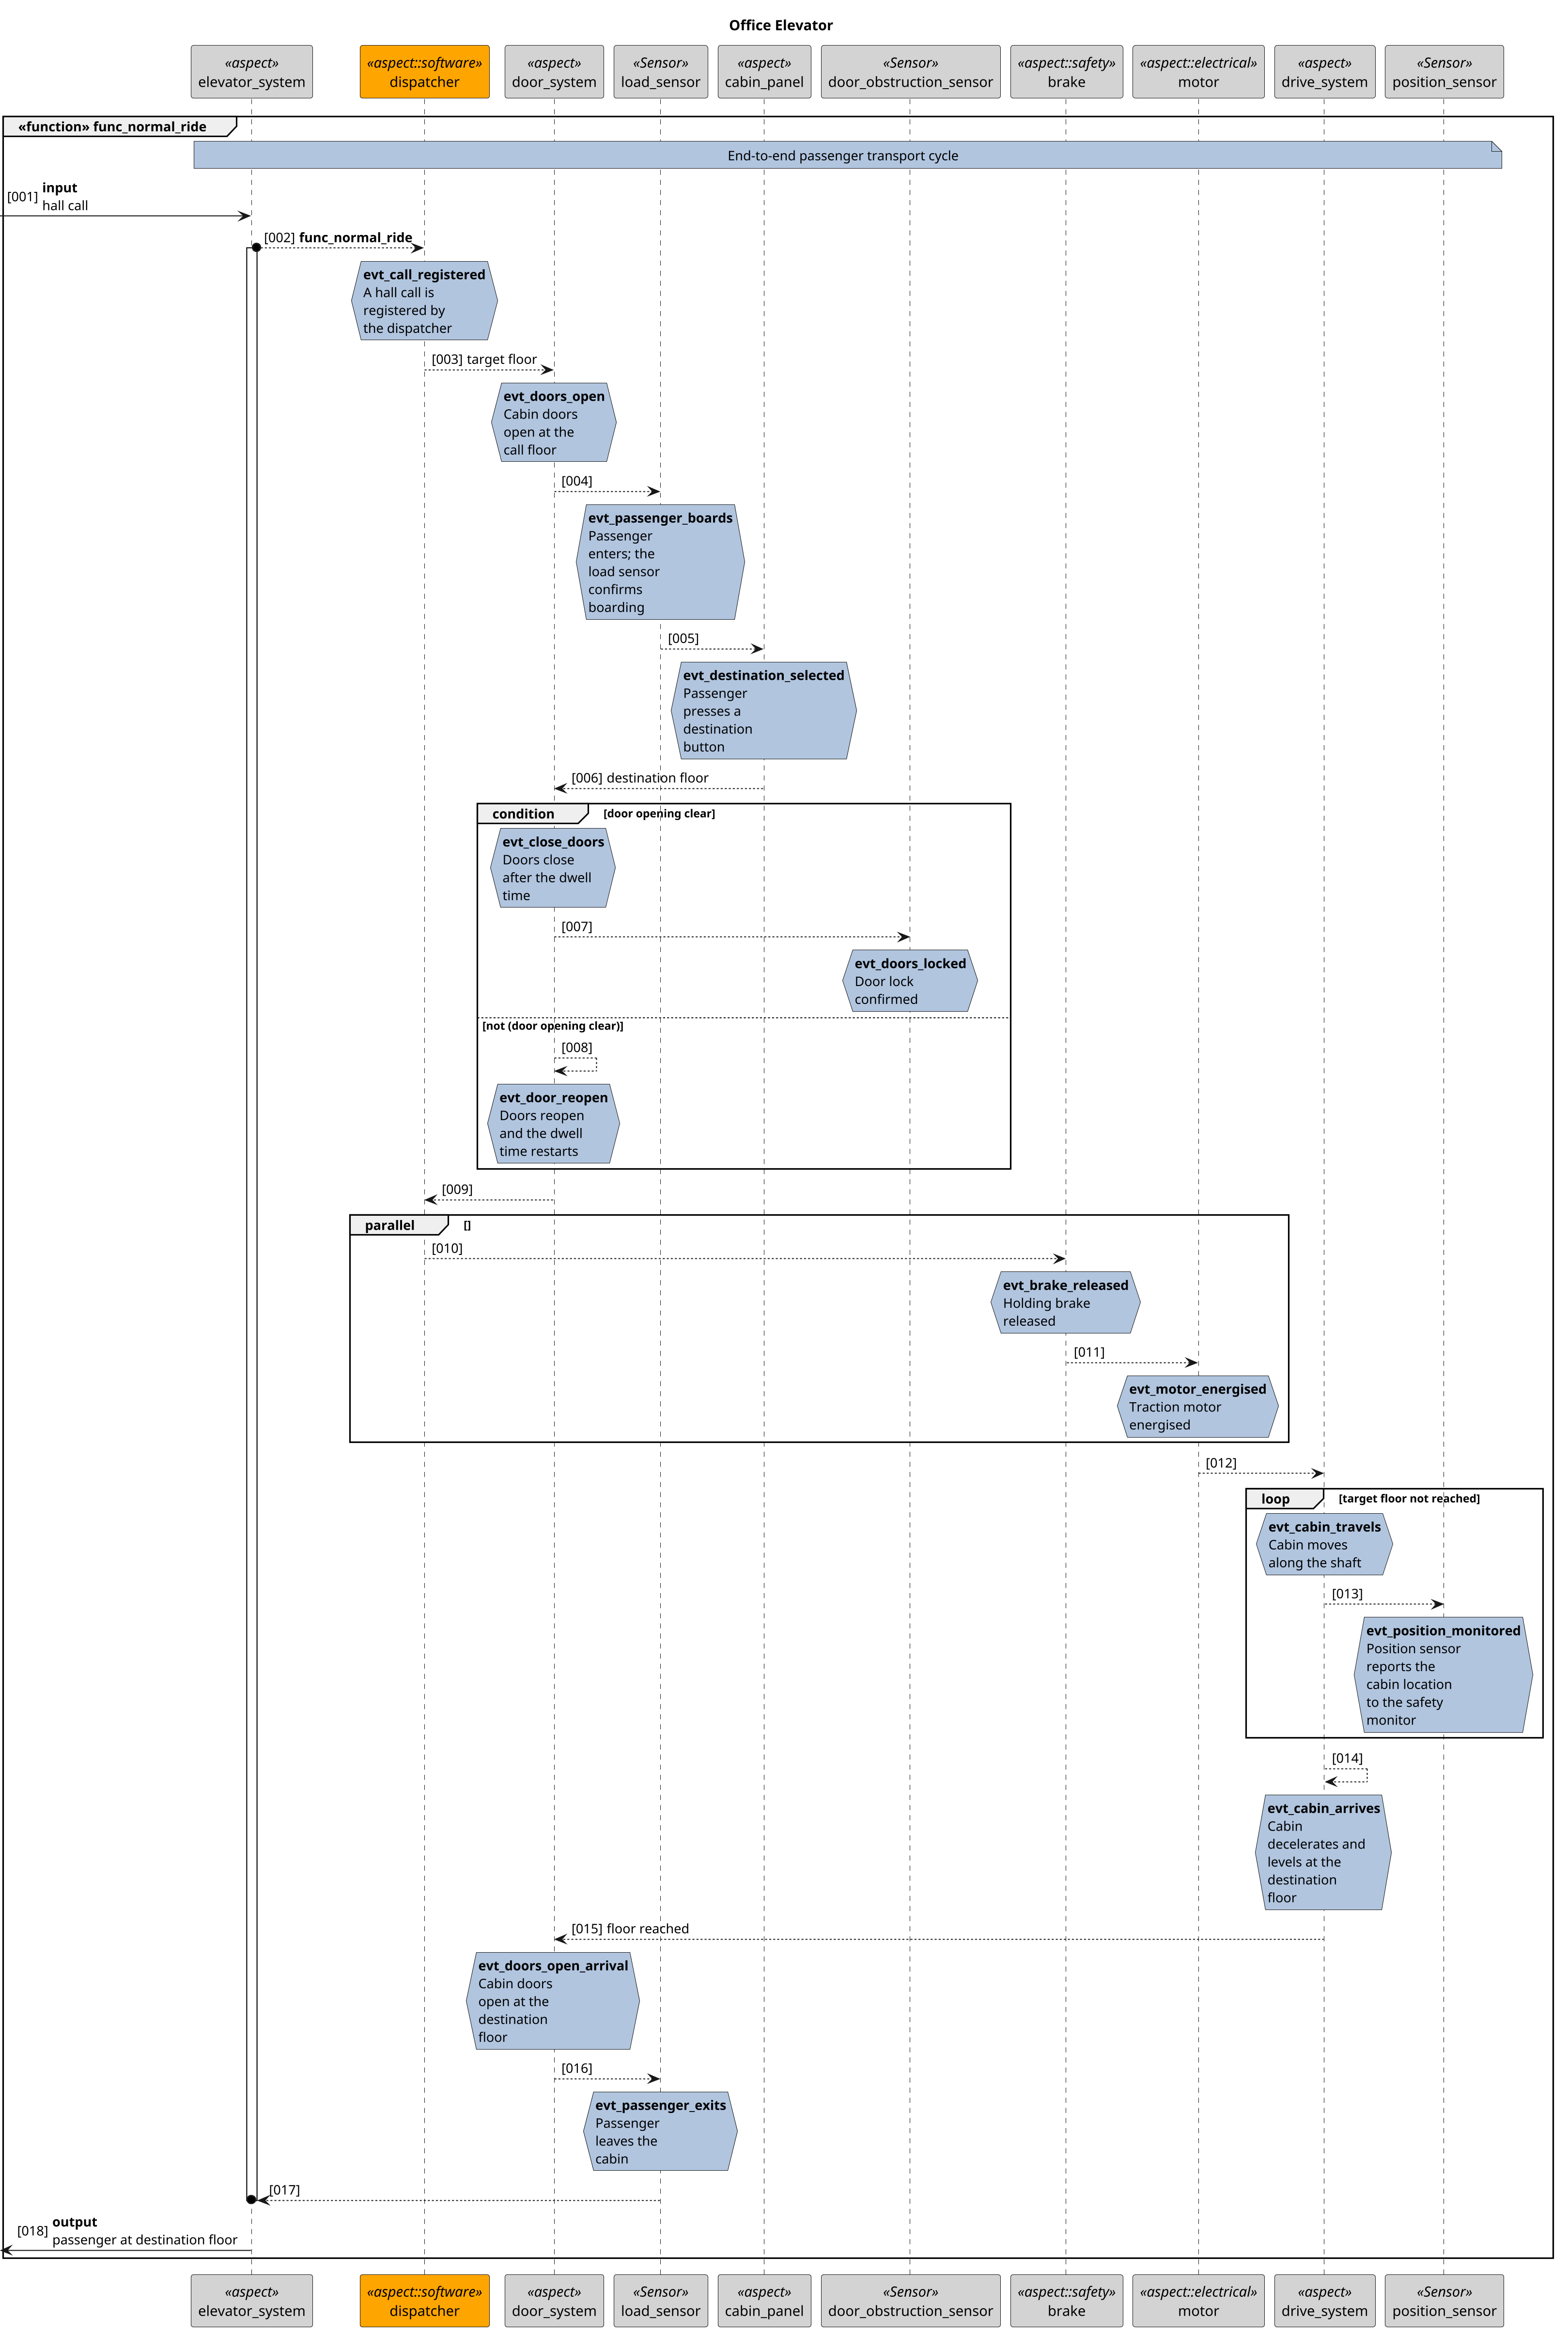
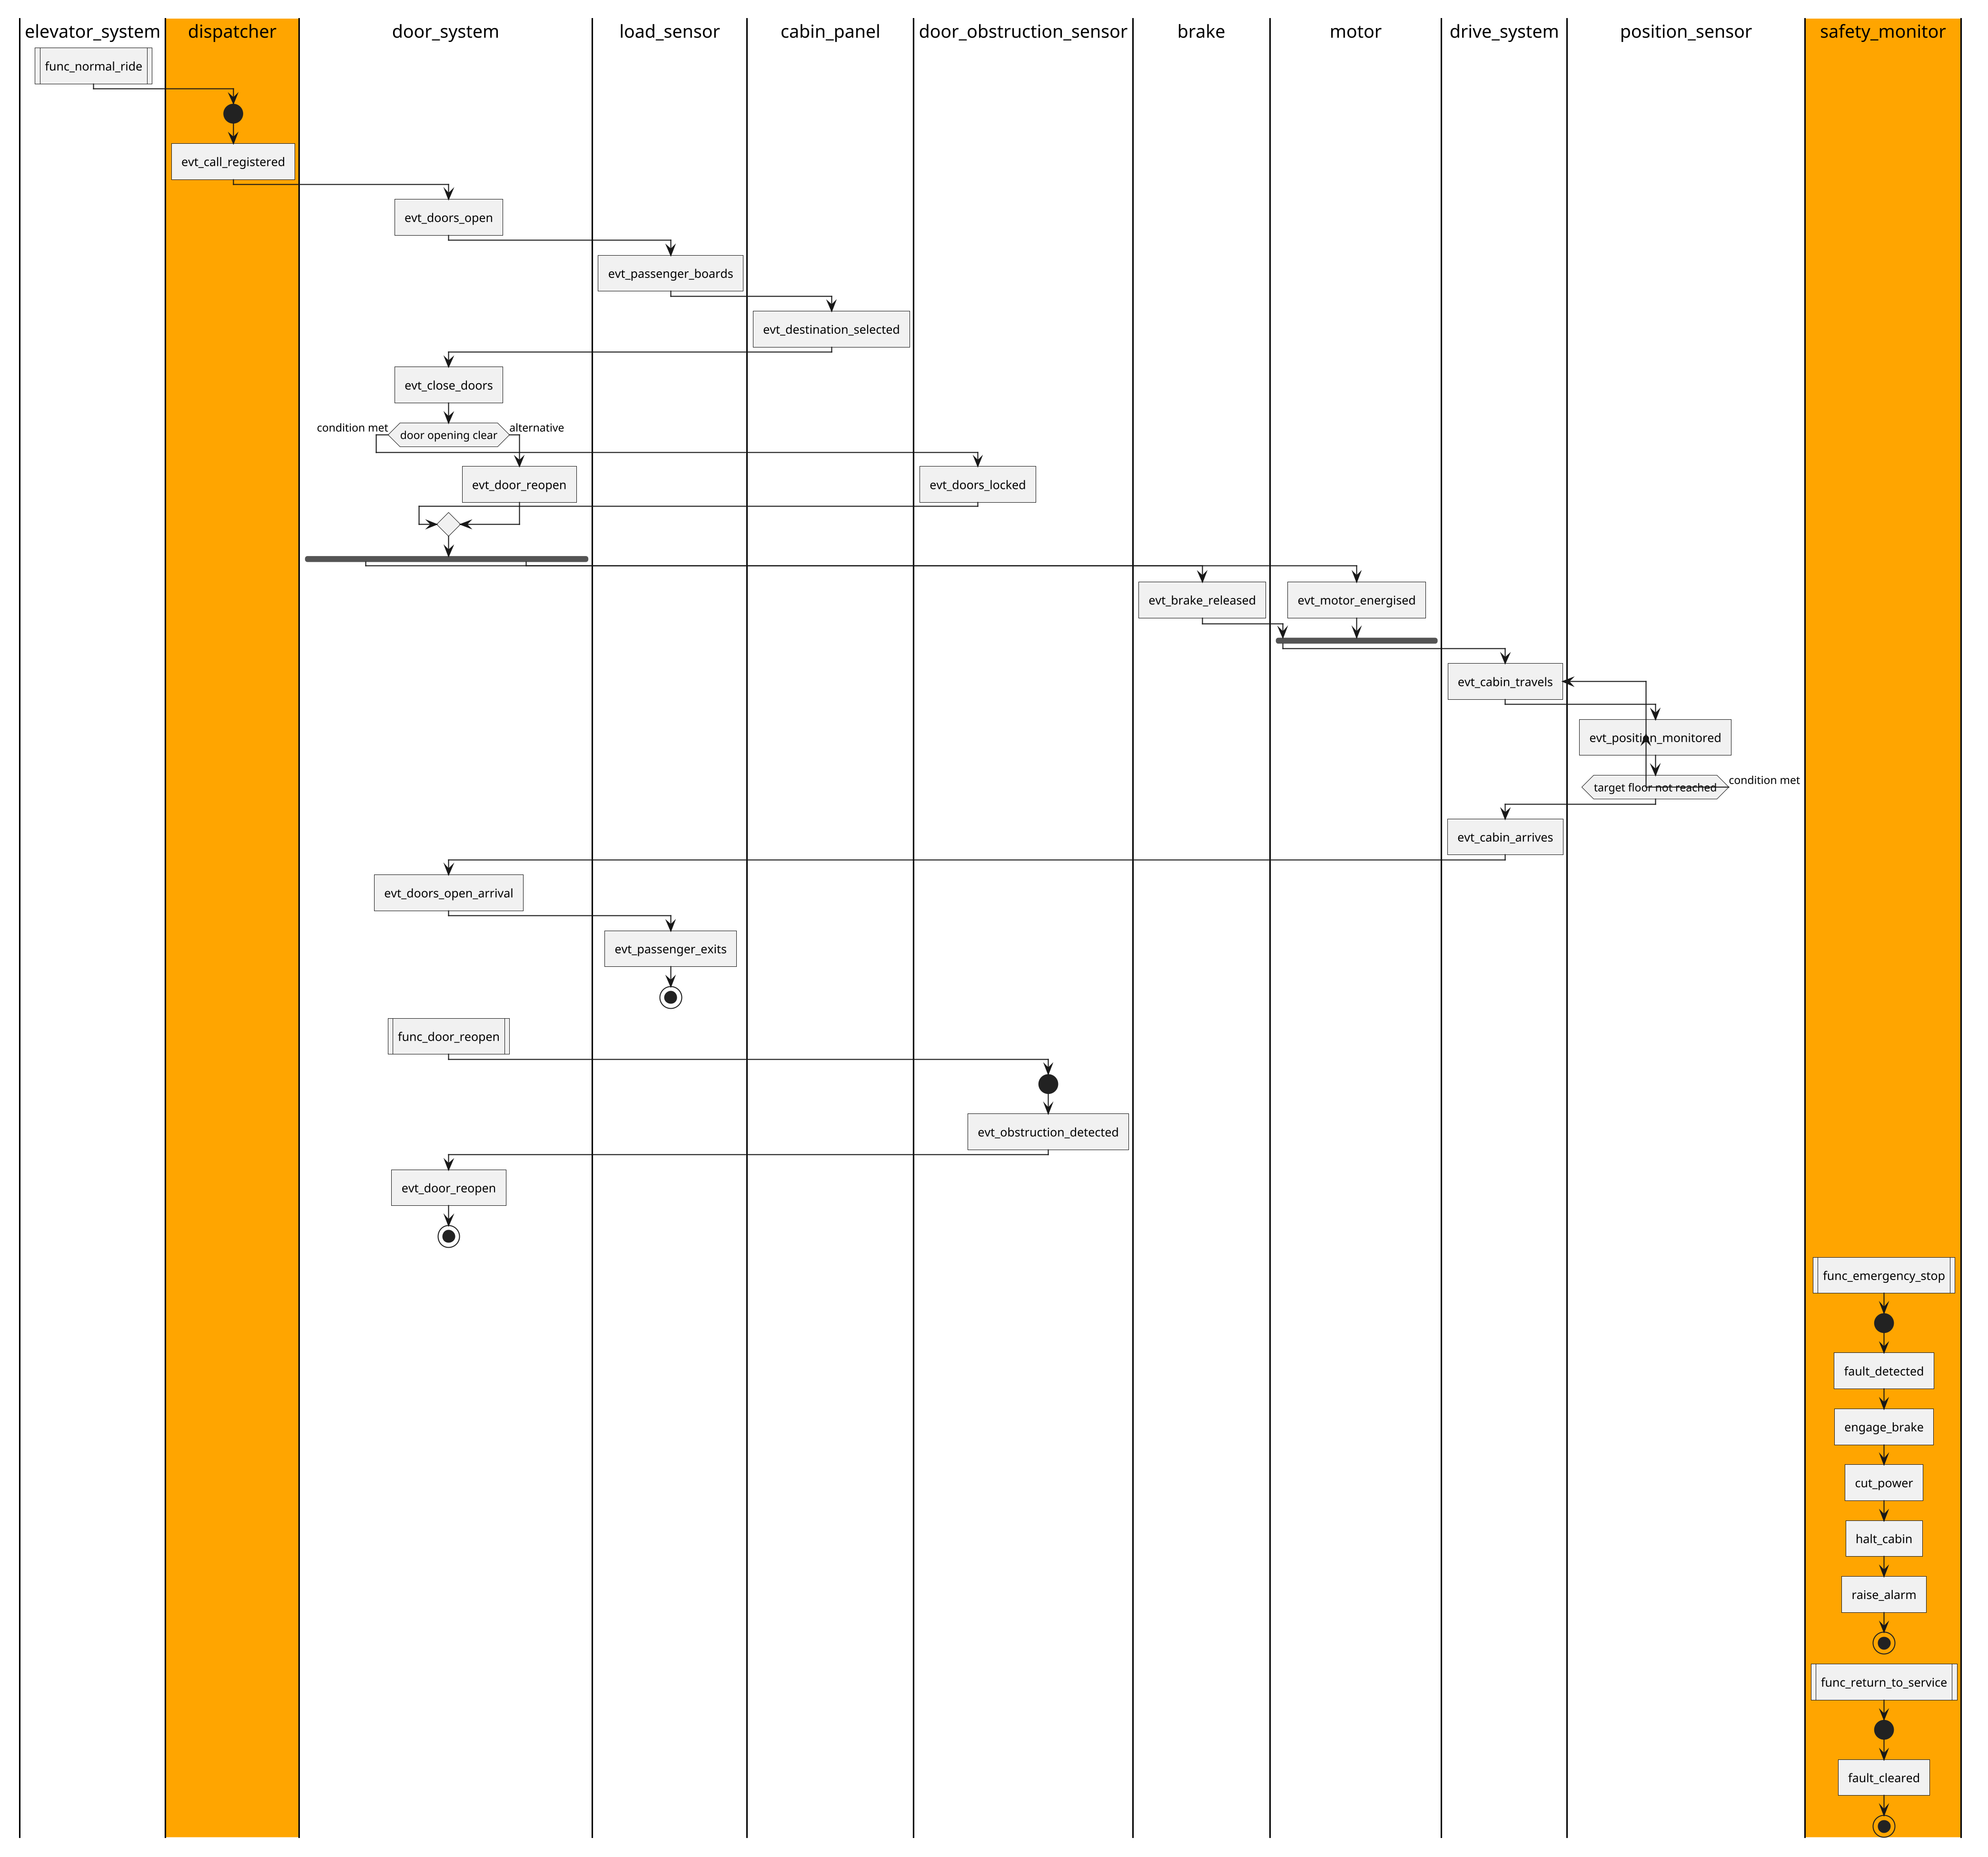
Passenger calls the elevator, boards, selects a floor and is transported
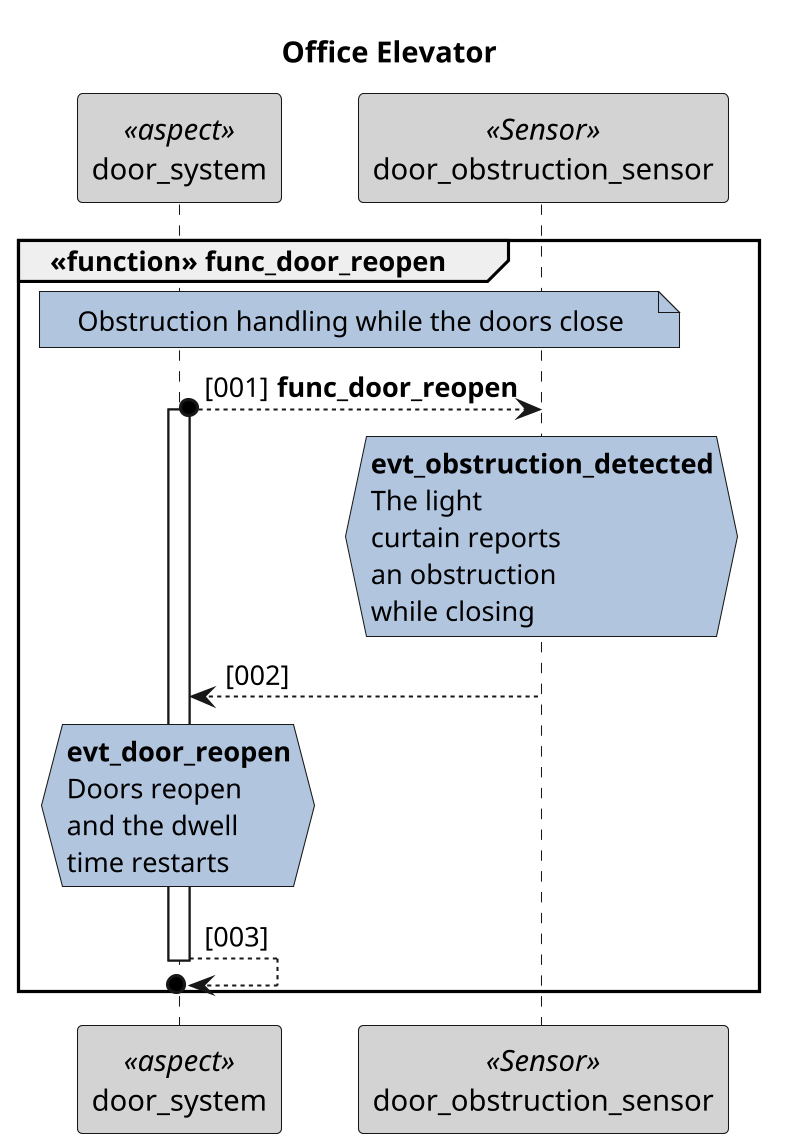
Aspect: elevator_system; requirement: sys_req_1; functions: func_normal_ride, func_door_reopen model/behaviour.sbdl:19
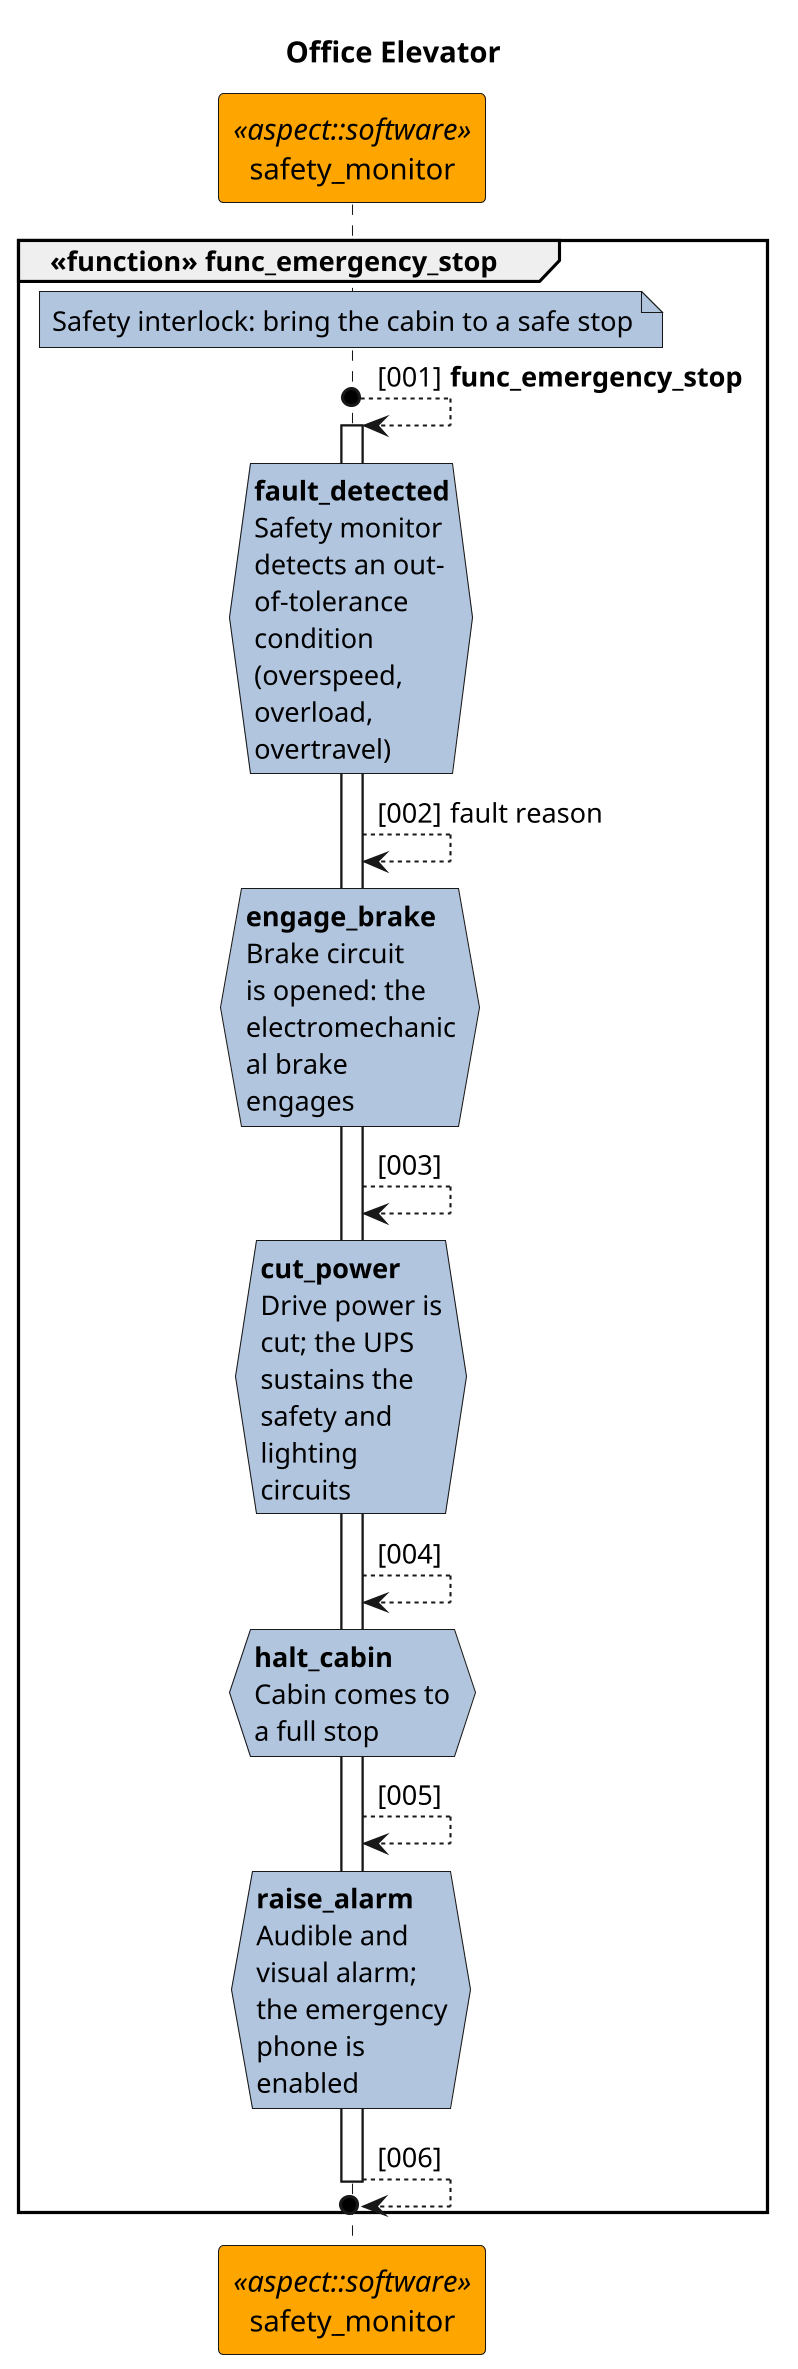
The safety monitor detects a fault and brings the cabin to a safe stop
Aspect: safety_monitor; requirement: sys_req_2; functions: func_emergency_stop model/behaviour.sbdl:43
Each function is a sequence of events; the diagrams are generated per
function with --diagram-root.
End-to-end passenger transport cycle in: hall call out: passenger at destination floor model/behaviour.sbdl:26
Obstruction handling while the doors close model/behaviour.sbdl:36
Safety interlock: bring the cabin to a safe stop src/controller.cpp:31
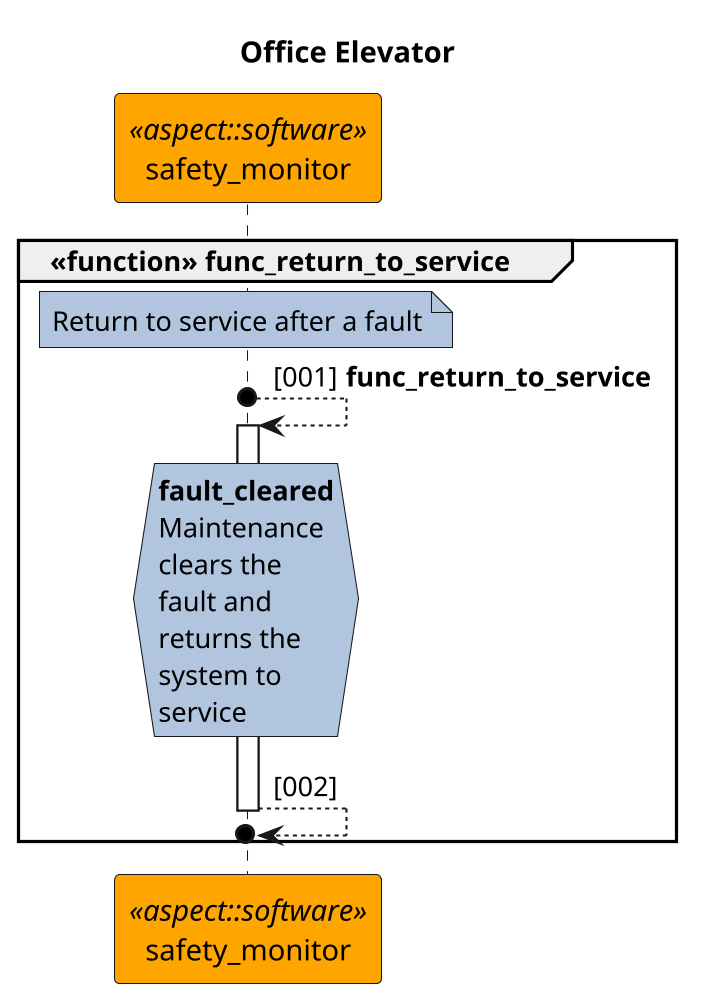
Return to service after a fault src/controller.cpp:78

| Transition | From | To | On event | Description |
|---|---|---|---|---|
| tr_idle_to_opening model/behaviour.sbdl:156 |
state_idle | state_doors_opening | evt_call_registered | Call received |
| tr_opening_to_boarding model/behaviour.sbdl:157 |
state_doors_opening | state_boarding | evt_doors_open | Doors fully open |
| tr_boarding_to_closing model/behaviour.sbdl:158 |
state_boarding | state_doors_closing | evt_close_doors | Dwell time elapsed |
| tr_closing_to_boarding model/behaviour.sbdl:159 |
state_doors_closing | state_boarding | evt_door_reopen | Obstruction: doors reopen |
| tr_closing_to_travelling model/behaviour.sbdl:160 |
state_doors_closing | state_travelling | evt_cabin_dispatched | Doors locked, cabin dispatched |
| tr_travelling_to_levelling model/behaviour.sbdl:161 |
state_travelling | state_levelling | evt_cabin_arrives | Approaching the floor |
| tr_levelling_to_opening model/behaviour.sbdl:162 |
state_levelling | state_doors_opening | evt_doors_open_arrival | Levelled: open the doors |
| tr_motion_to_fault model/behaviour.sbdl:163 |
state_in_motion | state_fault | fault_detected | Fault while in motion |
| tr_fault_to_idle model/behaviour.sbdl:164 |
state_fault | state_idle | fault_cleared | Fault cleared by maintenance |
Rows are generated from the failure modes, their effects, causes, controls and detections. RPN = severity × occurrence × detectability, before and after the planned actions.
| Aspect | Failure mode | Effect | S | Cause | O | Controls | Detection | D | RPN | Actions | RPN after |
|---|---|---|---|---|---|---|---|---|---|---|---|
| Cabin door mechanism and sensors | Cabin door fails to open at a floor | Passenger is unable to leave or enter the cabin | 8 | Door drive motor failure or mechanical jam | 3 | Scheduled preventive maintenance on the door drive motor; Monthly door obstruction test: block the light curtain while closing and confirm the doors reopen | Door position sensor confirms open/closed status on every cycle (The door system shall detect an obstruction and reopen within 250 ms) | 3 | 72 | Add a redundant door position sensor to detect a motor stall; Report a door-open timeout alarm to the building management system | 8 |
| Electromechanical holding and safety brake | Cabin exceeds its rated speed during travel | Risk of cabin impact at the shaft end; potential passenger injury | 10 | Electromechanical brake fails to hold under regenerative conditions | 2 | Annual brake inspection and load test per the EN 81-20 schedule | Centrifugal speed governor trips the safety gear on overspeed | 2 | 40 | Introduce a dual-redundant brake circuit with independent power supplies; Continuous speed logging with anomaly alerts to the maintenance system | 10 |
| Uninterruptible power supply for safety functions | Mains power lost while the cabin is between floors | Cabin halts between floors; passengers may be trapped until rescue (UPS sustains a controlled descent to the nearest floor) | 6 | Unplanned mains supply interruption | 4 | UPS sustains a controlled descent to the nearest floor | UPS self-test and mains voltage monitoring with continuous reporting | 1 | 24 | Automatic rescue drive: on power loss the UPS moves the cabin to the nearest floor and opens the doors | 12 |
| Action | Description | Owner | Due | Addresses |
|---|---|---|---|---|
| fa_ctrl_redundant_door_sensor model/safety.sbdl:87 |
Add a redundant door position sensor to detect a motor stall | Mechanical engineering | 2027-Q1 | fc_door_motor_failure |
| fa_det_door_timeout model/safety.sbdl:99 |
Report a door-open timeout alarm to the building management system | Controls engineering | fm_door_no_open | |
| fa_ctrl_dual_brake model/safety.sbdl:137 |
Introduce a dual-redundant brake circuit with independent power supplies | Electrical engineering | 2027-Q3 | fc_brake_failure |
| fa_det_speed_log model/safety.sbdl:150 |
Continuous speed logging with anomaly alerts to the maintenance system | Controls engineering | fm_overspeed | |
| fa_ctrl_auto_rescue model/safety.sbdl:187 |
Automatic rescue drive: on power loss the UPS moves the cabin to the nearest floor and opens the doors | Systems engineering | 2026-Q4 | fc_mains_interruption |
| Test | Checks that | Requirements | Detections |
|---|---|---|---|
| UT::test_stop_sequence src/controller_test.cpp:16 |
The brake engages before power is cut and the cabin halts | req_safety_brake | fd_speed_governor |
| UT::test_fault_cleared src/controller_test.cpp:23 |
A cleared fault returns the monitor to service | req_limit_switch | |
| UT::test_call_order src/controller_test.cpp:31 |
Calls are served in the order received | req_dispatch |
| Realisation | Description | Carries out |
|---|---|---|
| SafetyMonitor src/controller.cpp:27 |
The safety monitor realises the design decision recorded in model/elevator.sbdl | safety_monitor_design func_emergency_stop |
| Dispatcher_register_call src/controller.cpp:98 |
The dispatcher's call registration realises the first step of the normal ride | func_normal_ride |
Captured runs of the controller (logs/) are checked against the
functions and the state machine by sbdl -m trace:verify as part of
the build; a run that deviates from the model fails the build.
24 aspect3 customtype4 definition22 event3 fmea:cause4 fmea:control3 fmea:detection3 fmea:effect3 fmea:mode4 function1 group2 interface2 realisation8 requirement5 SafetyAction5 SafetyRequirement3 Sensor8 state3 test9 transition2 usecase
